Robotics · Computer vision · Embodied intelligence

Hritam Basak.

Teaching robots to see, reason, and act.

Scroll to discover
Hritam Basak overlooking the city
Hritam Basak · Researcher & scientist

A little about me

From seeing the world
to acting in it.

I develop whole-body control and manipulation policies for humanoid robots at Amazon Robotics. Working with the Fauna Robotics and Industrial Robotics groups, I turn language goals into navigation and manipulation behaviors through agentic navigation and skill orchestration.

My research spans 3D vision & robotics, vision-language-action models, generative AI, and multimodal learning (Vision + X), with applications in medical image analysis. I also mentor interns working on dexterous manipulation and robust grasping in cluttered environments.

I completed my Ph.D. in Computer Science at Stony Brook University in May 2026, advised by Prof. Zhaozheng Yin. Previously: two research internships at Amazon, data science at Tata Digital / Tata Neu, and research visits at ETH Zurich and Sorbonne University. I earned my B.E. in Electrical Engineering from Jadavpur University.

  • VLA Models
  • Manipulation
  • Diffusion Models
  • 3D Generation
  • Domain Adaptation
20+Publications
CVPR · ECCVNeurIPS · MICCAI
9+Awards & grants
3Continents of research

Ideas in motion

Research directions

Perception, action, and learning in the physical world.

Along the way

Recent updates

Earlier updates · 9 entries
  • Honored to receive the ICCV/CVF Travel Grant and the IEEE RAS Travel Award for IROS 2025.
  • Our "ViSPLA" paper was accepted to NeurIPS 2025!
  • Our "D4Recon" paper was accepted to MICCAI 2025 and our Gaussian Splatting work to IROS 2025!
  • Back at Amazon for a second research internship on VLA models and manipulation.
  • Two papers, "SemiDAViL" and "UA-Pose," were accepted at CVPR 2025!
  • Received the IEEE SPS Scholarship for the second consecutive year.
  • Thrilled to receive the MICCAI NIH Travel Award and the ECCV DEI Award.
  • Our paper "Forget More to Learn More" was accepted at ECCV 2024.
  • Our "Quest for Clone" paper was accepted at MICCAI 2024.

Selected work

Selected publications

Robotics, 3D vision, and learning from limited supervision.

All publications on Scholar

2026

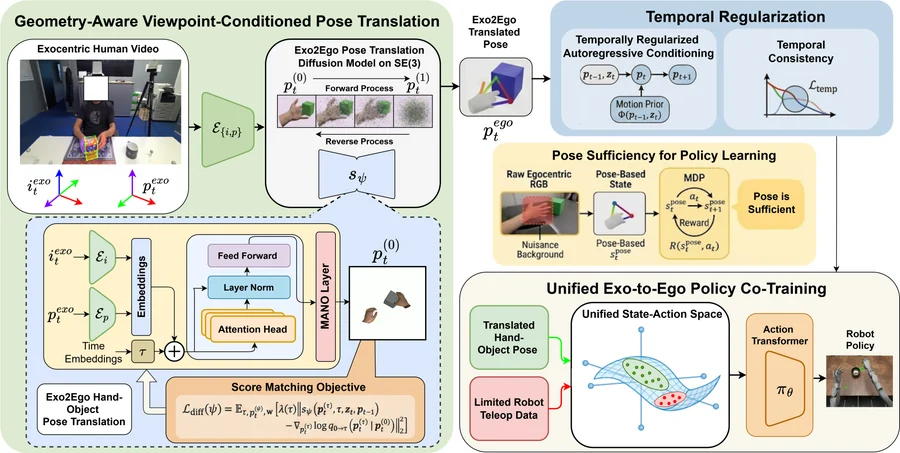
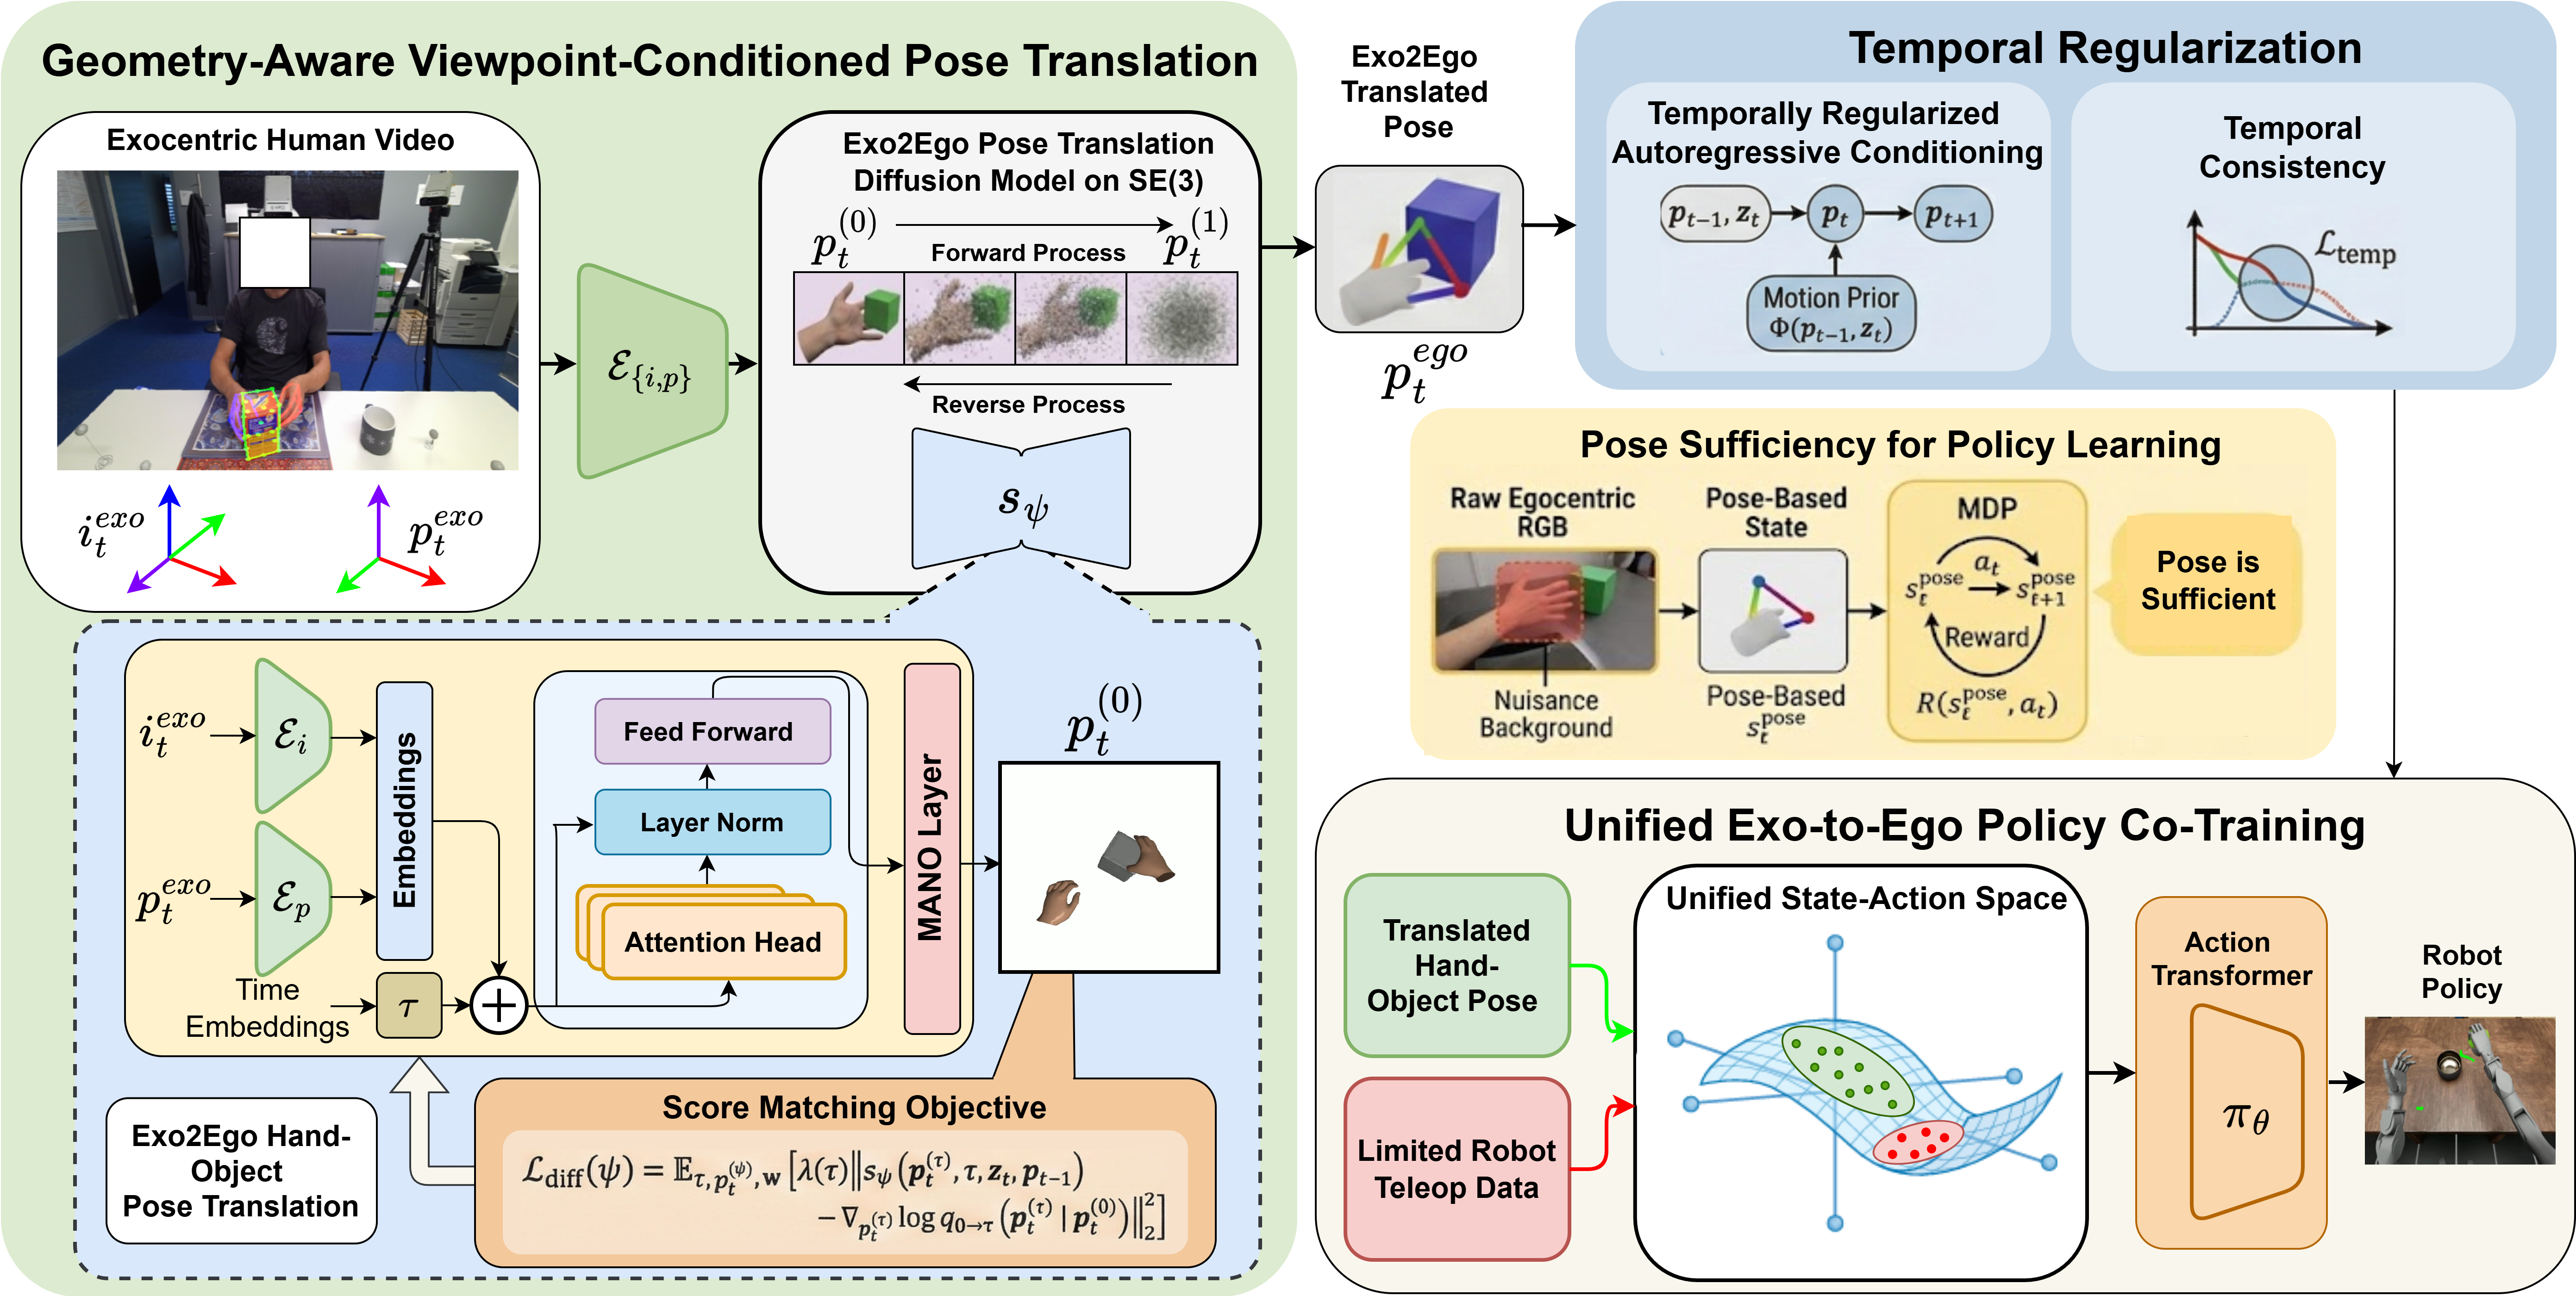
Research figure for Exo2EgoPolicy: Pose-Aligned Cross-View Policy Learning

ECCV 2026

Exo2EgoPolicy: Pose-Aligned Cross-View Policy Learning

Hritam Basak, Hadi Tabatabaee, Shreekant Gayaka, Xin Yang, Cheng-Hao Kuo, Zhaozheng Yin, Min Sun

Project ↗

We present an end-to-end video generation and policy-learning pipeline for exocentric-to-egocentric viewpoint translation, enabling transformative progress in imitation learning and advancing the frontier of embodied AI.

BibTeX citation
@inproceedings{basak2026exo2ego,
  title = {Exo2EgoPolicy: Pose-Aligned Cross-View Policy Learning},
  author = {Basak, Hritam and Tabatabaee, Hadi and Gayaka, Shreekant and Yang, Xin and Kuo, Cheng-Hao and Yin, Zhaozheng and Sun, Min},
  booktitle = {ECCV},
  year = {2026}
}
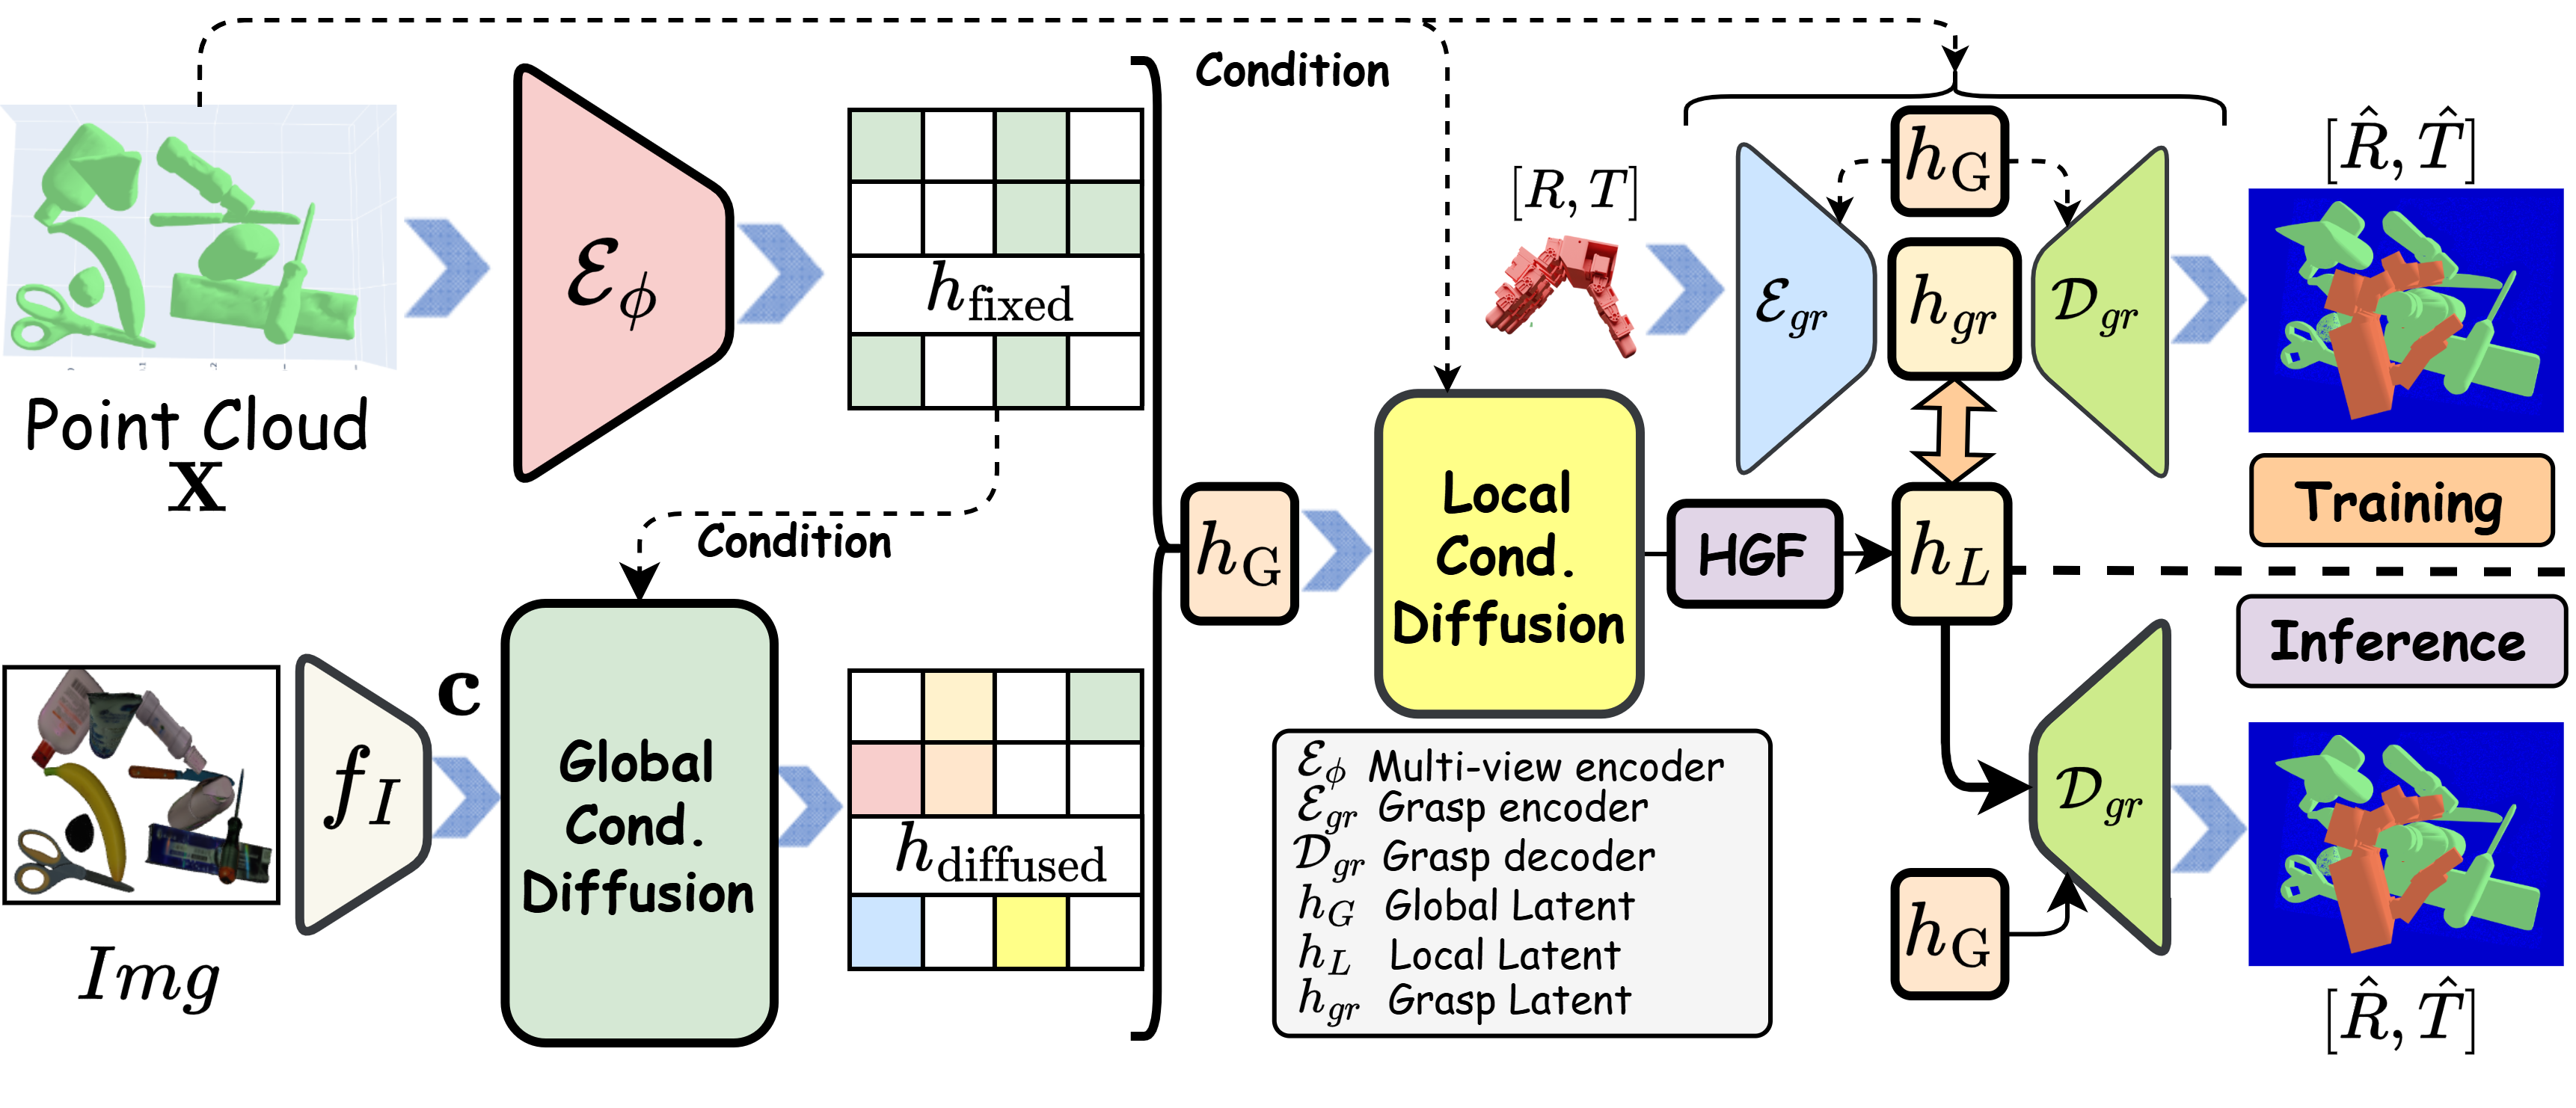
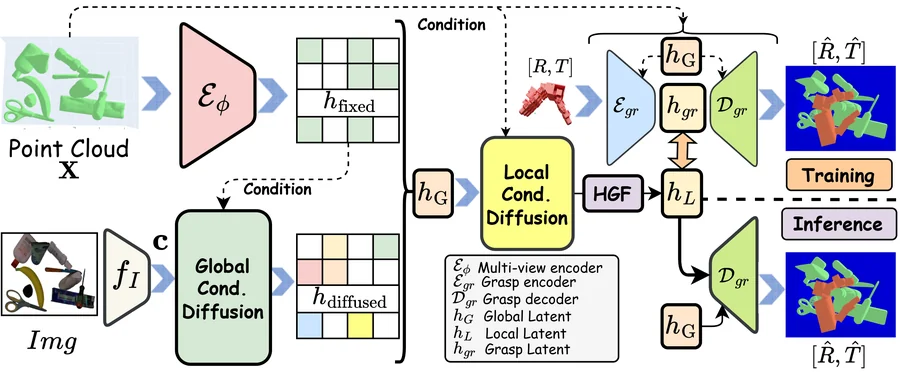
Research figure for Fixed Reality, Diffused Possibility: Disentangling Stochastic and Deterministic Latent for Cluttered Grasping

ECCV 2026

Fixed Reality, Diffused Possibility: Disentangling Stochastic and Deterministic Latent for Cluttered Grasping

Hritam Basak, Zhaozheng Yin

Project ↗ Code ↗

We propose a split-latent hierarchical diffusion framework that disentangles deterministic geometric priors (fixed latent) from stochastic scene-level context (diffused latent) for reliable affordance-grasp prediction in cluttered, partially observed environments. A Global Conditional Diffusion produces the stochastic latent from RGB context, a Local Conditional Diffusion predicts dense point-wise affordance and grasp fields, and a Harmonic Grasp Field enforces smooth, obstacle-aware grasp manifolds, yielding physically consistent and uncertainty-aware grasp generation.

BibTeX citation
@inproceedings{basak2026fixed,
  title = {Fixed Reality, Diffused Possibility: Disentangling Stochastic and Deterministic Latent for Cluttered Grasping},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {ECCV},
  year = {2026}
}
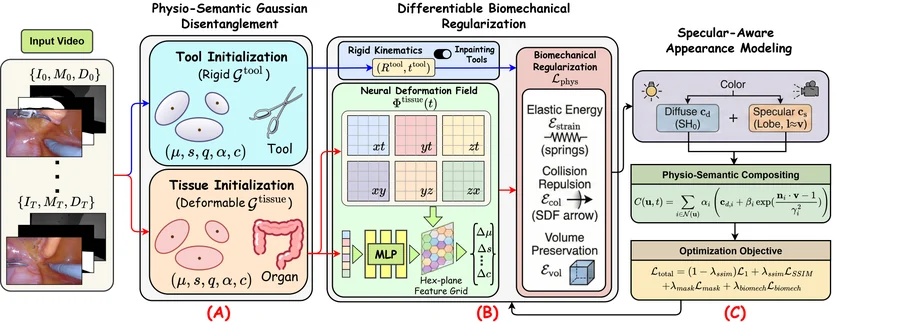
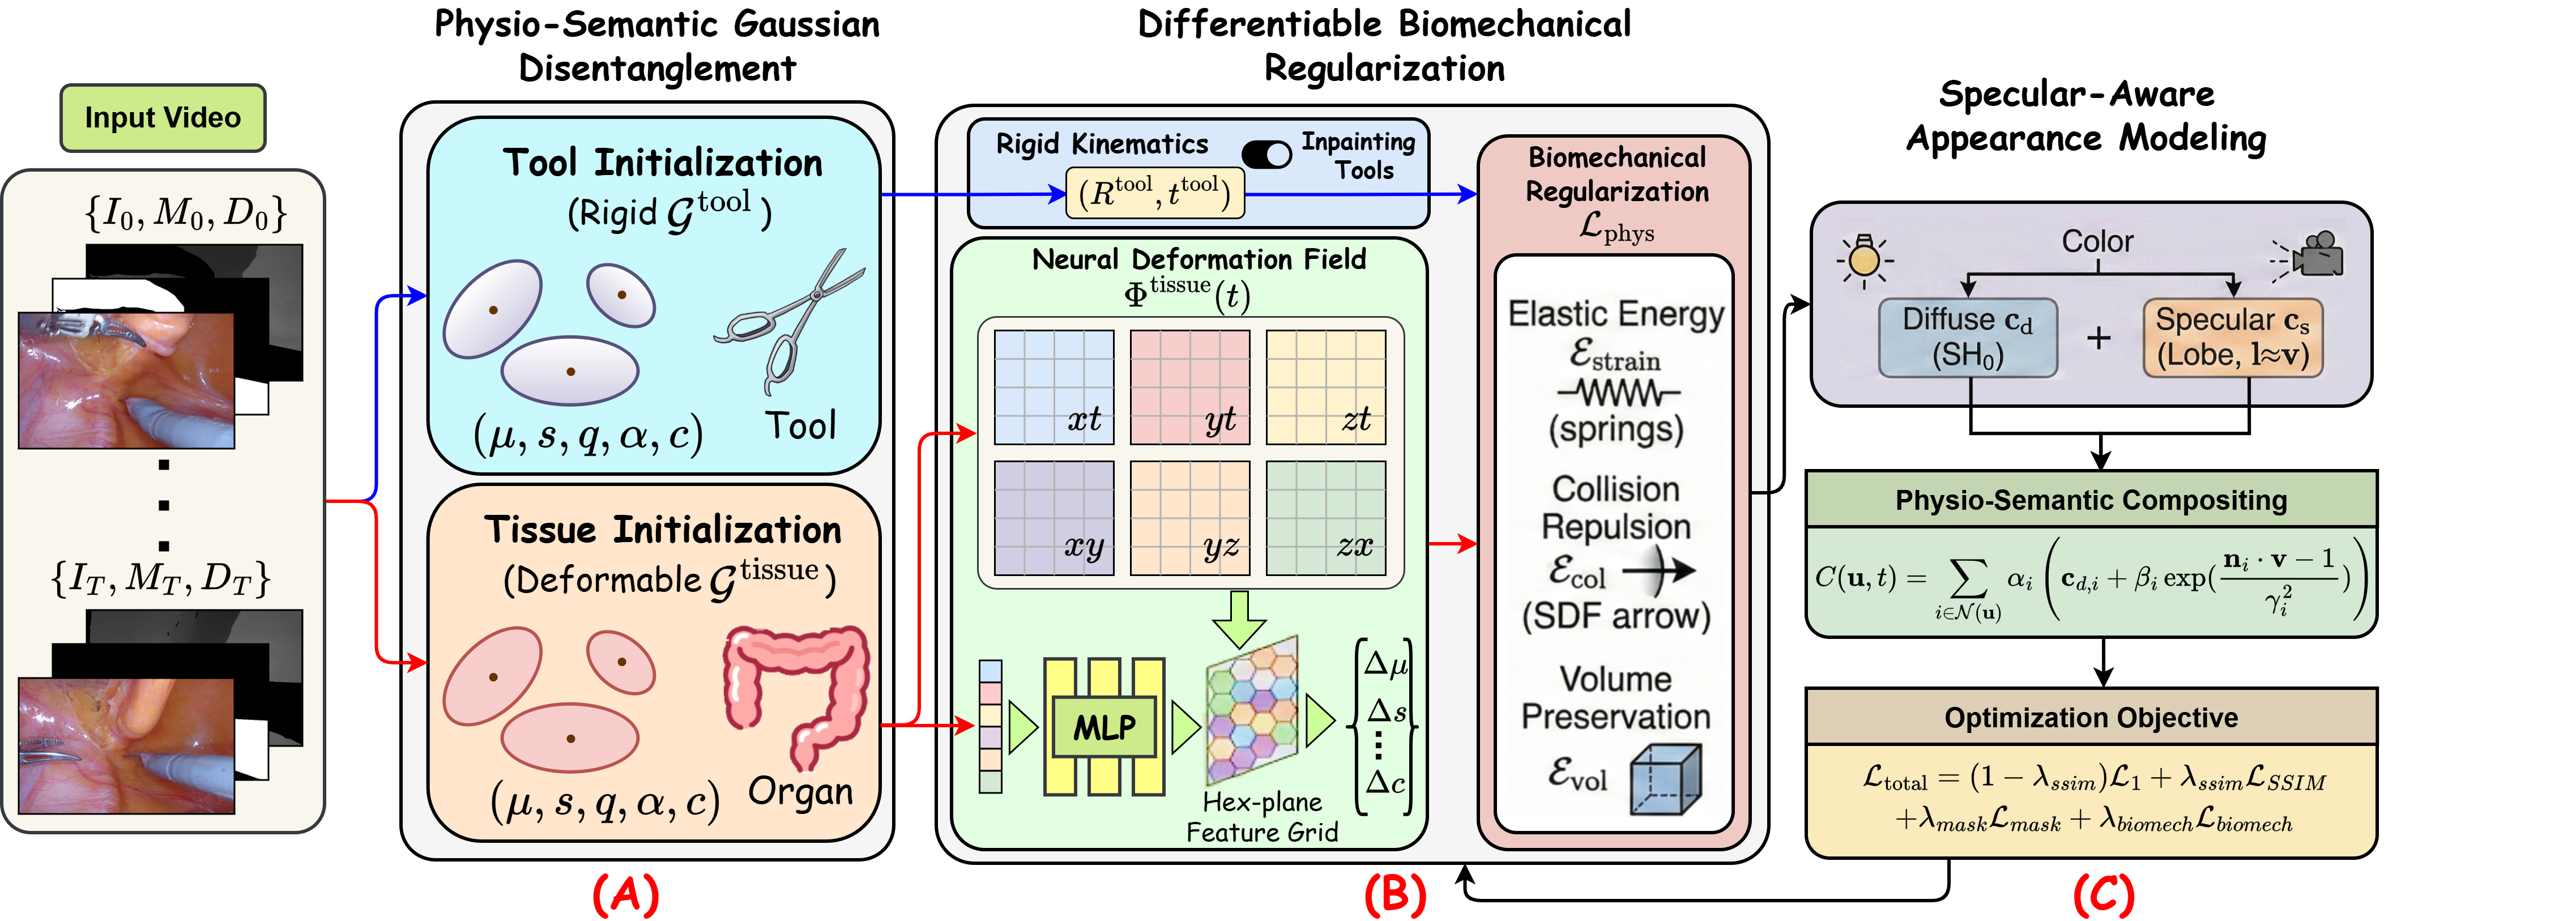
Research figure for PhysioSplat: Physics-Informed Dynamic Gaussian Splatting for Surgical Scene Reconstruction

MICCAI 2026

PhysioSplat: Physics-Informed Dynamic Gaussian Splatting for Surgical Scene Reconstruction

Hritam Basak, Zhaozheng Yin

Project ↗

We introduce PhysioSplat, a physics-informed dynamic Gaussian Splatting framework for surgical scene reconstruction, embedding physical priors into deformable tissue modeling for geometrically coherent, real-time endoscopic rendering.

BibTeX citation
@inproceedings{basak2026physiosplat,
  title = {PhysioSplat: Physics-Informed Dynamic Gaussian Splatting for Surgical Scene Reconstruction},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {MICCAI},
  year = {2026}
}

2025

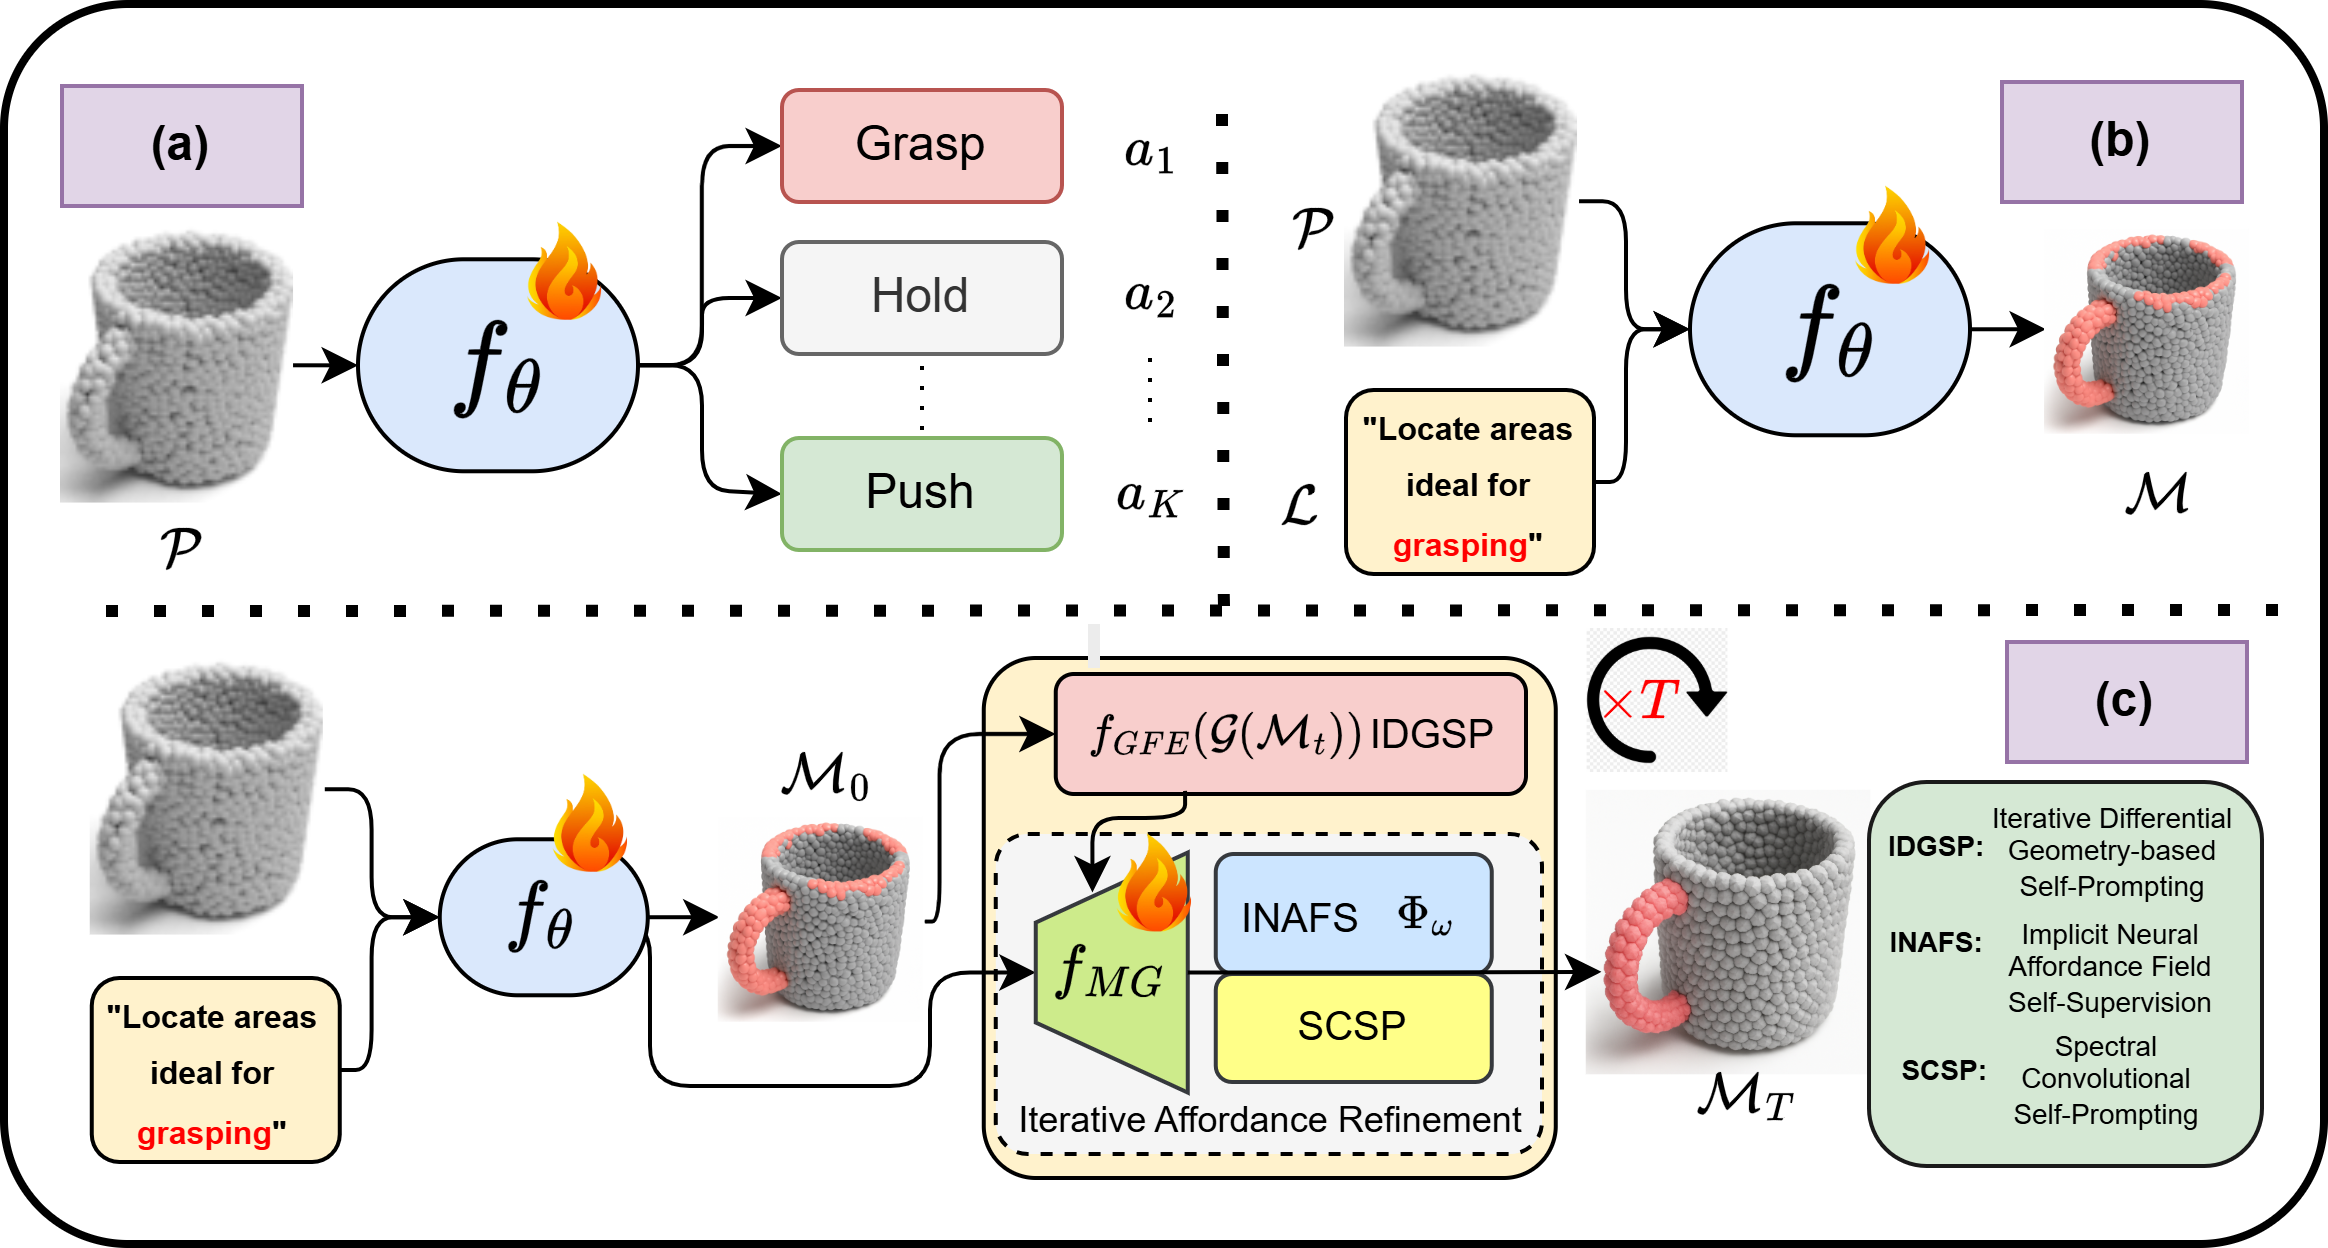
Research figure for ViSPLA: Visual Iterative Self-Prompting for Language-Guided 3D Affordance Learning

NeurIPS 2025

ViSPLA: Visual Iterative Self-Prompting for Language-Guided 3D Affordance Learning

Hritam Basak, Zhaozheng Yin

Project ↗

We devise a Visual Iterative Self-Prompting algorithm with Neural Affordance Field supervision for language-guided 3D affordance estimation, enabling robots to ground language instructions in 3D actionable regions.

BibTeX citation
@inproceedings{basak2025vispla,
  title = {ViSPLA: Visual Iterative Self-Prompting for Language-Guided 3D Affordance Learning},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {NeurIPS},
  year = {2025}
}
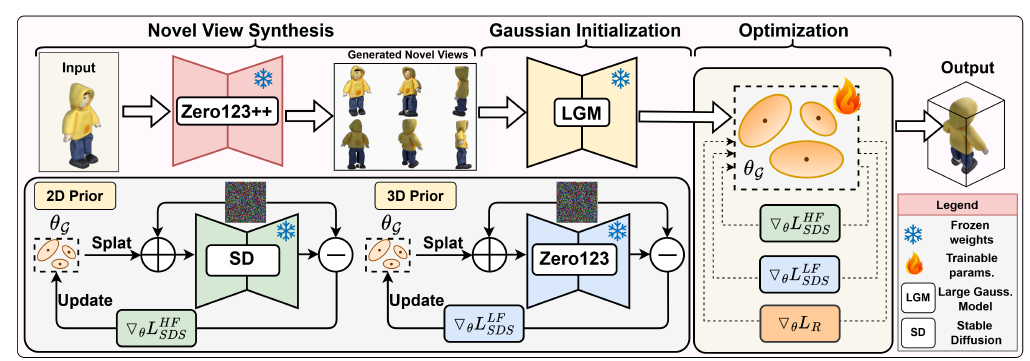
Research figure for Enhancing Single Image to 3D Generation using Gaussian Splatting and Hybrid Diffusion Priors

IROS 2025

Enhancing Single Image to 3D Generation using Gaussian Splatting and Hybrid Diffusion Priors

Hritam Basak, Hadi Tabatabaee, Shreekant Gayaka, Ming-Feng Li, Xin Yang, Cheng-Hao Kuo, Arnie Sen, Min Sun, Zhaozheng Yin

Paper ↗

3D object generation from a single unposed RGB image is essential for robotic perception... Our approach achieves state-of-the-art 3D reconstruction quality, significantly improving robotic perception pipelines.

BibTeX citation
@inproceedings{basak2025enhancing,
  title = {Enhancing Single Image to 3D Generation using Gaussian Splatting and Hybrid Diffusion Priors},
  author = {Basak, Hritam and Tabatabaee, Hadi and Gayaka, Shreekant and Li, Ming-Feng and Yang, Xin and Kuo, Cheng-Hao and Sen, Arnie and Sun, Min and Yin, Zhaozheng},
  booktitle = {IROS},
  year = {2025}
}
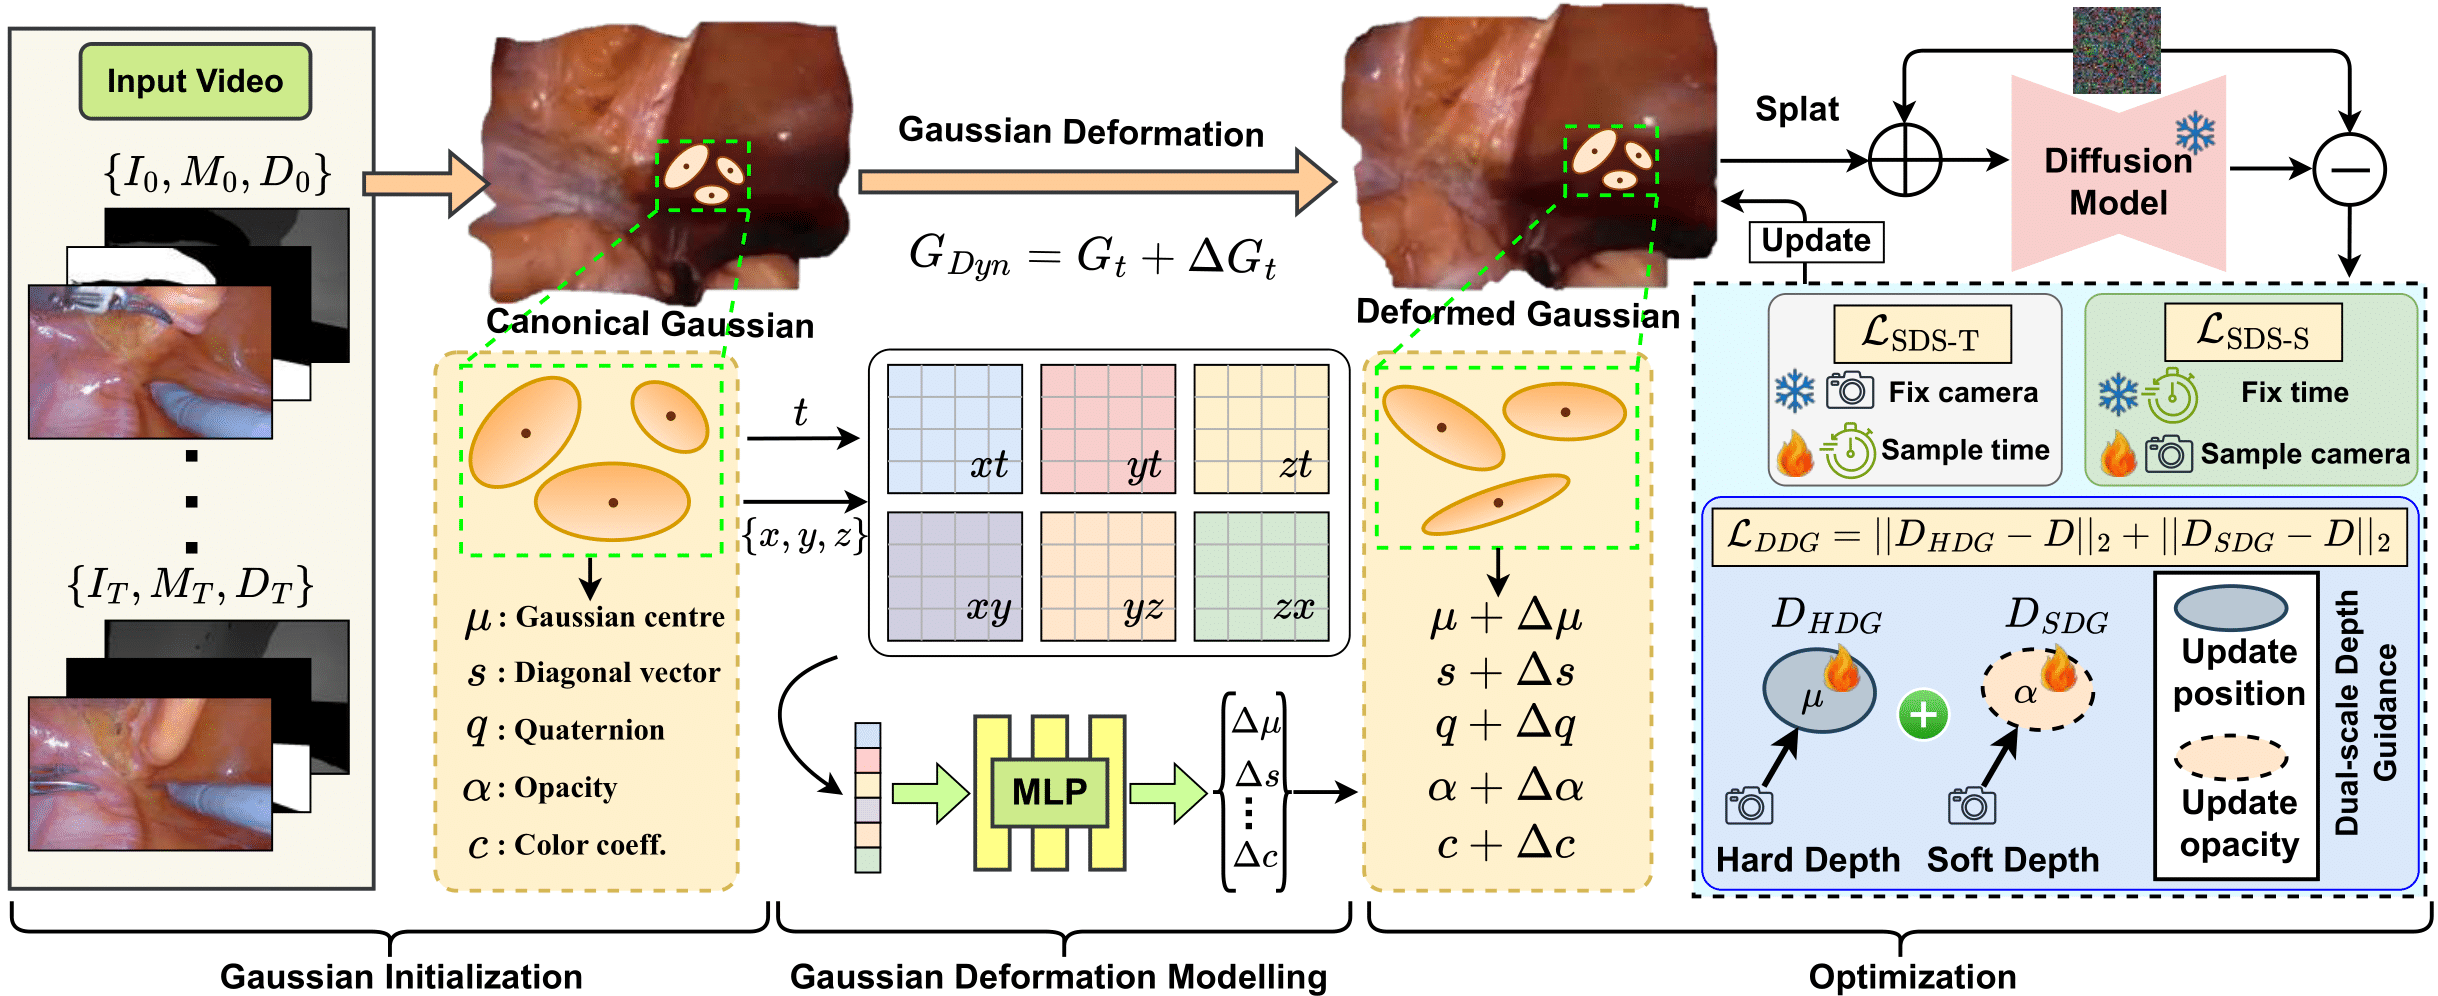
Research figure for D4Recon: Dual-stage Deformation and Dual-scale Depth Guidance for Endoscopic Reconstruction

MICCAI 2025

D4Recon: Dual-stage Deformation and Dual-scale Depth Guidance for Endoscopic Reconstruction

Hritam Basak, Zhaozheng Yin

Project ↗ Code ↗

Deformable tissue reconstruction in endoscopy is vital for surgery... D4Recon achieves superior geometric coherence and photorealism with real-time rendering speed, outperforming existing methods.

BibTeX citation
@inproceedings{basak2025d4recon,
  title = {D4Recon: Dual-stage Deformation and Dual-scale Depth Guidance for Endoscopic Reconstruction},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {MICCAI},
  year = {2025}
}
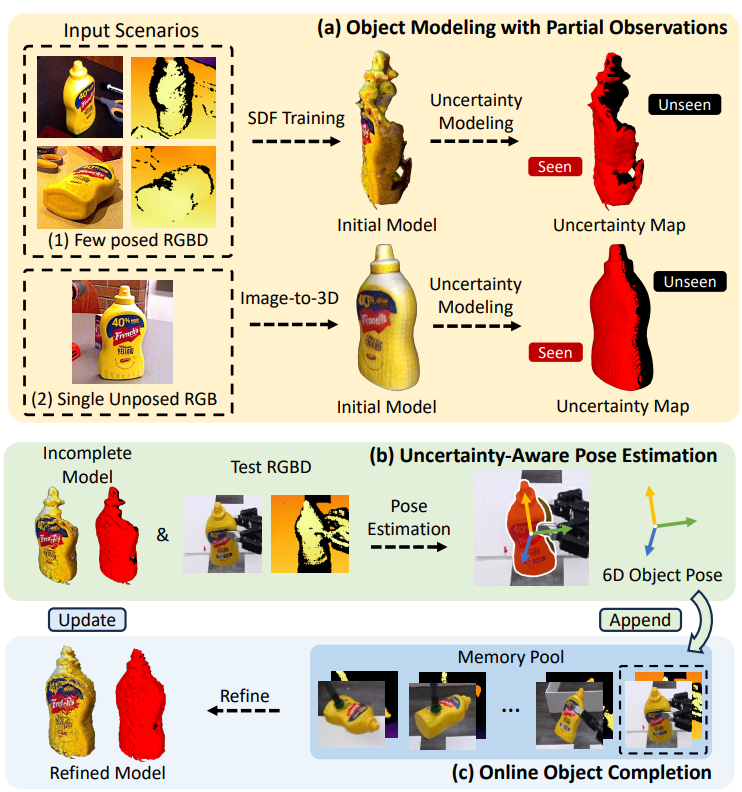
Research figure for UA-Pose: Uncertainty-aware 6D Object Pose Estimation and Online Object Completion with Partial References

CVPR 2025

UA-Pose: Uncertainty-aware 6D Object Pose Estimation and Online Object Completion with Partial References

Ming-Feng Li, Xin Yang, Fu-En Wang, Hritam Basak, Yuyin Sun, Shreekant Gayaka, Min Sun, Cheng-Hao Kuo

Paper ↗ Code ↗

We propose UA-Pose, an uncertainty-aware approach for 6D object pose estimation... Experimental results demonstrate significant performance improvements.

BibTeX citation
@inproceedings{li2025ua,
  title = {UA-Pose: Uncertainty-aware 6D Object Pose Estimation and Online Object Completion with Partial References},
  author = {Li, Ming-Feng and Yang, Xin and Wang, Fu-En and Basak, Hritam and Sun, Yuyin and Gayaka, Shreekant and Sun, Min and Kuo, Cheng-Hao},
  booktitle = {CVPR},
  year = {2025}
}
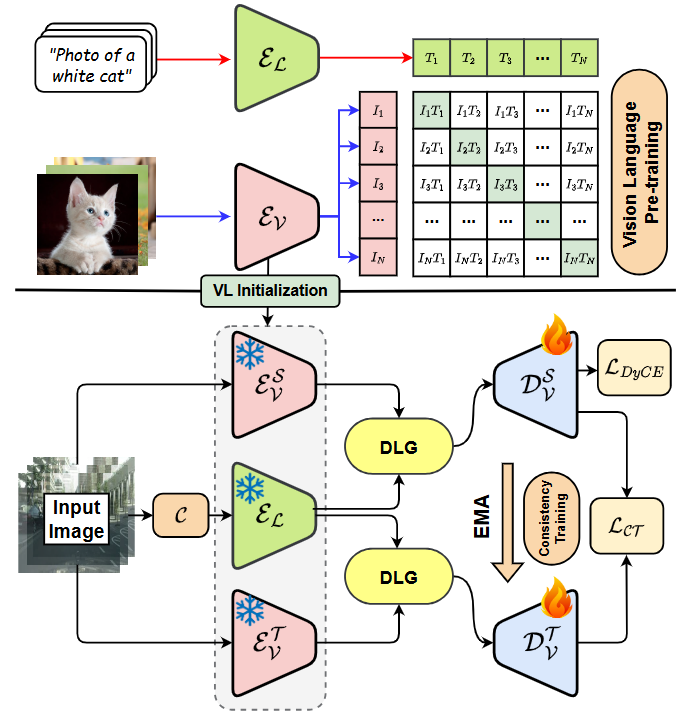
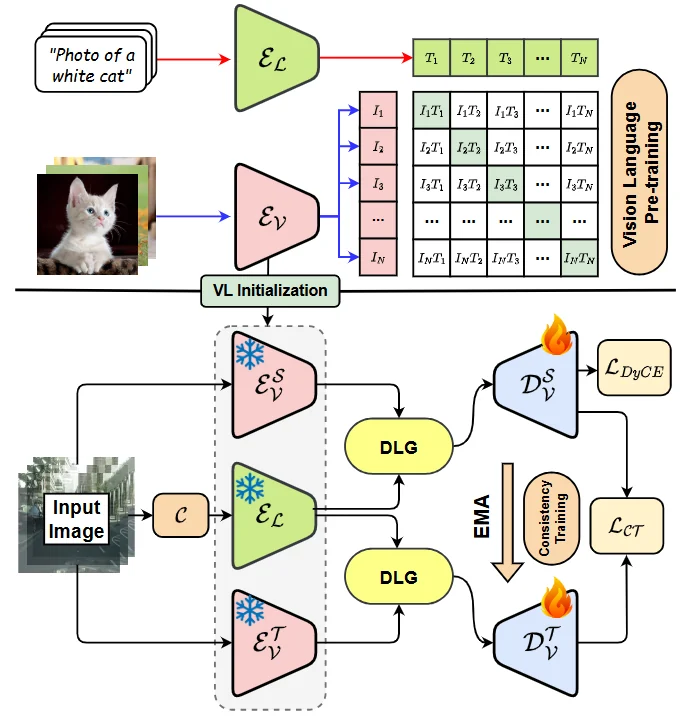
Research figure for SemiDAViL: Semi-supervised Domain Adaptation with Vision-Language Guidance for Semantic Segmentation

CVPR 2025

SemiDAViL: Semi-supervised Domain Adaptation with Vision-Language Guidance for Semantic Segmentation

Hritam Basak, Zhaozheng Yin

Paper ↗ Code ↗

We propose the first language-guided SSDA setting for semantic segmentation. We harness the semantic generalization capabilities inherent in vision-language models (VLMs).

BibTeX citation
@inproceedings{basak2025semidavil,
  title = {SemiDAViL: Semi-supervised Domain Adaptation with Vision-Language Guidance for Semantic Segmentation},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {CVPR},
  year = {2025}
}

2024

Research figure for Forget More to Learn More: Domain-specific Feature Unlearning for Semi-supervised and Unsupervised Domain Adaptation

ECCV 2024

Forget More to Learn More: Domain-specific Feature Unlearning for Semi-supervised and Unsupervised Domain Adaptation

Hritam Basak, Zhaozheng Yin

Paper ↗ Code ↗

In pursuit of greater generalizability and robustness, we present an SSDA framework with a new episodic learning strategy: "learn, forget, then learn more".

BibTeX citation
@inproceedings{basak2024forget,
  title = {Forget More to Learn More: Domain-specific Feature Unlearning for Semi-supervised and Unsupervised Domain Adaptation},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {ECCV},
  year = {2024}
}
Research figure for Quest for Clone: Test-Time Domain Adaptation for Medical Image Segmentation by Searching the Closest Clone in Latent Space

MICCAI 2024

Quest for Clone: Test-Time Domain Adaptation for Medical Image Segmentation by Searching the Closest Clone in Latent Space

Hritam Basak, Zhaozheng Yin

Paper ↗ Code ↗

We propose a generative latent search paradigm to reconstruct the closest clone of every target image from the source latent space... We empirically validate the efficacy of our proposed method.

BibTeX citation
@inproceedings{basak2024quest,
  title = {Quest for Clone: Test-Time Domain Adaptation for Medical Image Segmentation by Searching the Closest Clone in Latent Space},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {MICCAI},
  year = {2024}
}

2023

Research figure for Pseudo Label Guided Contrastive Learning for Semi-supervised Medical Image Segmentation

CVPR 2023

Pseudo Label Guided Contrastive Learning for Semi-supervised Medical Image Segmentation

Hritam Basak, Zhaozheng Yin

Paper ↗ Code ↗

We propose a novel semi-supervised patch-based CL framework for medical image segmentation... Experimental analysis reveals the superiority of our proposed method.

BibTeX citation
@inproceedings{basak2023pseudo,
  title = {Pseudo Label Guided Contrastive Learning for Semi-supervised Medical Image Segmentation},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {CVPR},
  year = {2023}
}
Research figure for Semi-supervised Domain Adaptive Medical Image Segmentation through Consistency Regularized Disentangled Contrastive Learning

MICCAI 2023

Semi-supervised Domain Adaptive Medical Image Segmentation through Consistency Regularized Disentangled Contrastive Learning

Hritam Basak, Zhaozheng Yin

Paper ↗ Code ↗

We investigate semi-supervised domain adaptation (SSDA) for medical image segmentation... Our proposed method outperforms the SoTA methods.

BibTeX citation
@inproceedings{basak2023semi,
  title = {Semi-supervised Domain Adaptive Medical Image Segmentation through Consistency Regularized Disentangled Contrastive Learning},
  author = {Basak, Hritam and Yin, Zhaozheng},
  booktitle = {MICCAI},
  year = {2023}
}

2022

Research figure for Addressing Class Imbalance in Semi-supervised Image Segmentation: A Study on Cardiac MRI

MICCAI 2022

Addressing Class Imbalance in Semi-supervised Image Segmentation: A Study on Cardiac MRI

Hritam Basak, Sagnik Ghosal, Ram Sarkar

Paper ↗

To alleviate the shortcoming of class imbalance, we propose maintaining a confidence array that records class-wise performance during training.

BibTeX citation
@inproceedings{basak2022addressing,
  title = {Addressing Class Imbalance in Semi-supervised Image Segmentation: A Study on Cardiac MRI},
  author = {Basak, Hritam and Ghosal, Sagnik and Sarkar, Ram},
  booktitle = {MICCAI},
  year = {2022}
}
Research figure for An Exceedingly Simple Consistency Regularization Method for Semi-Supervised Medical Image Segmentation

ISBI 2022

An Exceedingly Simple Consistency Regularization Method for Semi-Supervised Medical Image Segmentation

Hritam Basak, Rajarshi Bhattacharya, Rukhshanda Hussain, Agniv Chatterjee

Paper ↗ Code ↗

We introduce a novel regularization strategy involving interpolation-based mixing for semi-supervised medical image segmentation.

BibTeX citation
@inproceedings{basak2022exceedingly,
  title = {An Exceedingly Simple Consistency Regularization Method for Semi-Supervised Medical Image Segmentation},
  author = {Basak, Hritam and Bhattacharya, Rajarshi and Hussain, Rukhshanda and Chatterjee, Agniv},
  booktitle = {ISBI},
  year = {2022}
}

The research community

Academic service

Conference reviewing

  • CVPR (2024, 2025)
  • MICCAI (2023, 2024, 2025)
  • ECCV (2024) · ICCV (2025)
  • IJCAI · AAAI (2023, 2024, 2025)
  • ICASSP

Journal reviewing

  • IEEE TPAMI · TNNLS · TIP · TCSVT · TMI
  • Elsevier Medical Image Analysis · Pattern Recognition
  • Nature
  • International Journal of Computer Vision (IJCV)

Teaching assistant, Stony Brook University · CSE377: Medical Imaging · CSE214: Introduction to Data Structures

Awards & recognition
  • ICCV/CVF Travel Grant · 2025
  • IEEE RAS Travel Award · 2025
  • ECCV DEI Award · 2024
  • MICCAI NIH Travel Grant · 2024
  • IEEE SPS Scholarship · 2023 & 2024
  • IEEE ICASSP Travel Grant · 2022
  • MICCAI STAR Award · 2022
  • Gandhi Fellowship · 2021
  • Charpak Fellowship · 2020

Let’s build together

Let’s move
ideas forward.

Always open to collaboration. Whether it's robotics & manipulation, vision-language-action models, generative AI, or medical imaging — if you have an exciting idea or want to chat about research, I'd love to hear from you.

Get in touch

Where to?

About me 01 ↗Research directions ↗Recent updates 02 ↗Selected publications 03 ↗Academic service 04 ↗Let's collaborate 05 ↗Download CV PDF ↗

Search, tab to a destination, and press enter. esc to close.

Research figure

Selected research figure
Open original image ↗